4x4s.org NAMED MODEL · 2010
NAMED MODELUnited Kingdom

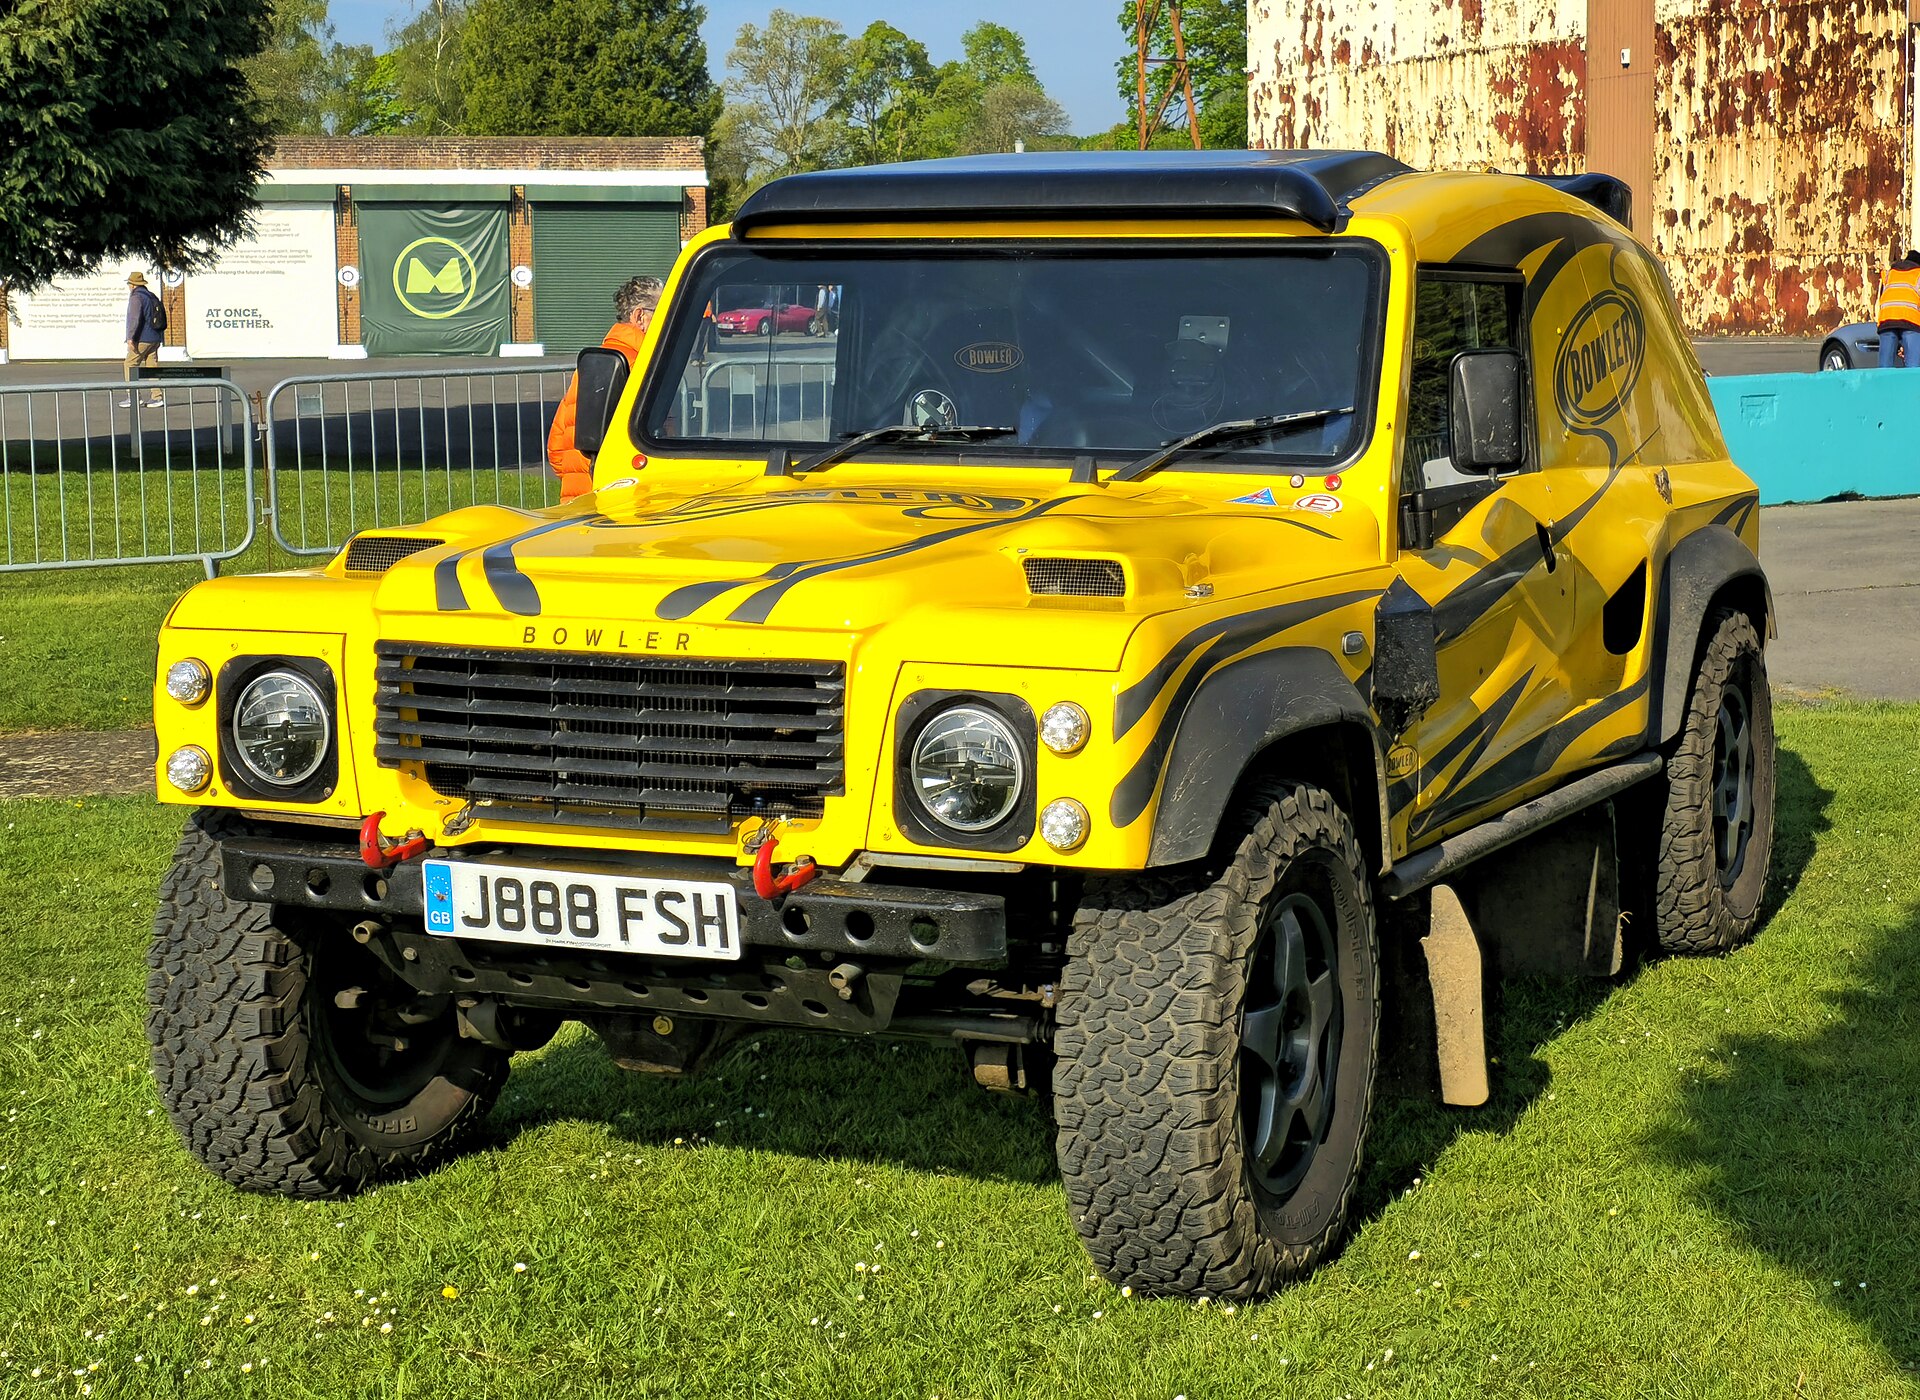
Wildcat (BAE Systems autonomous)

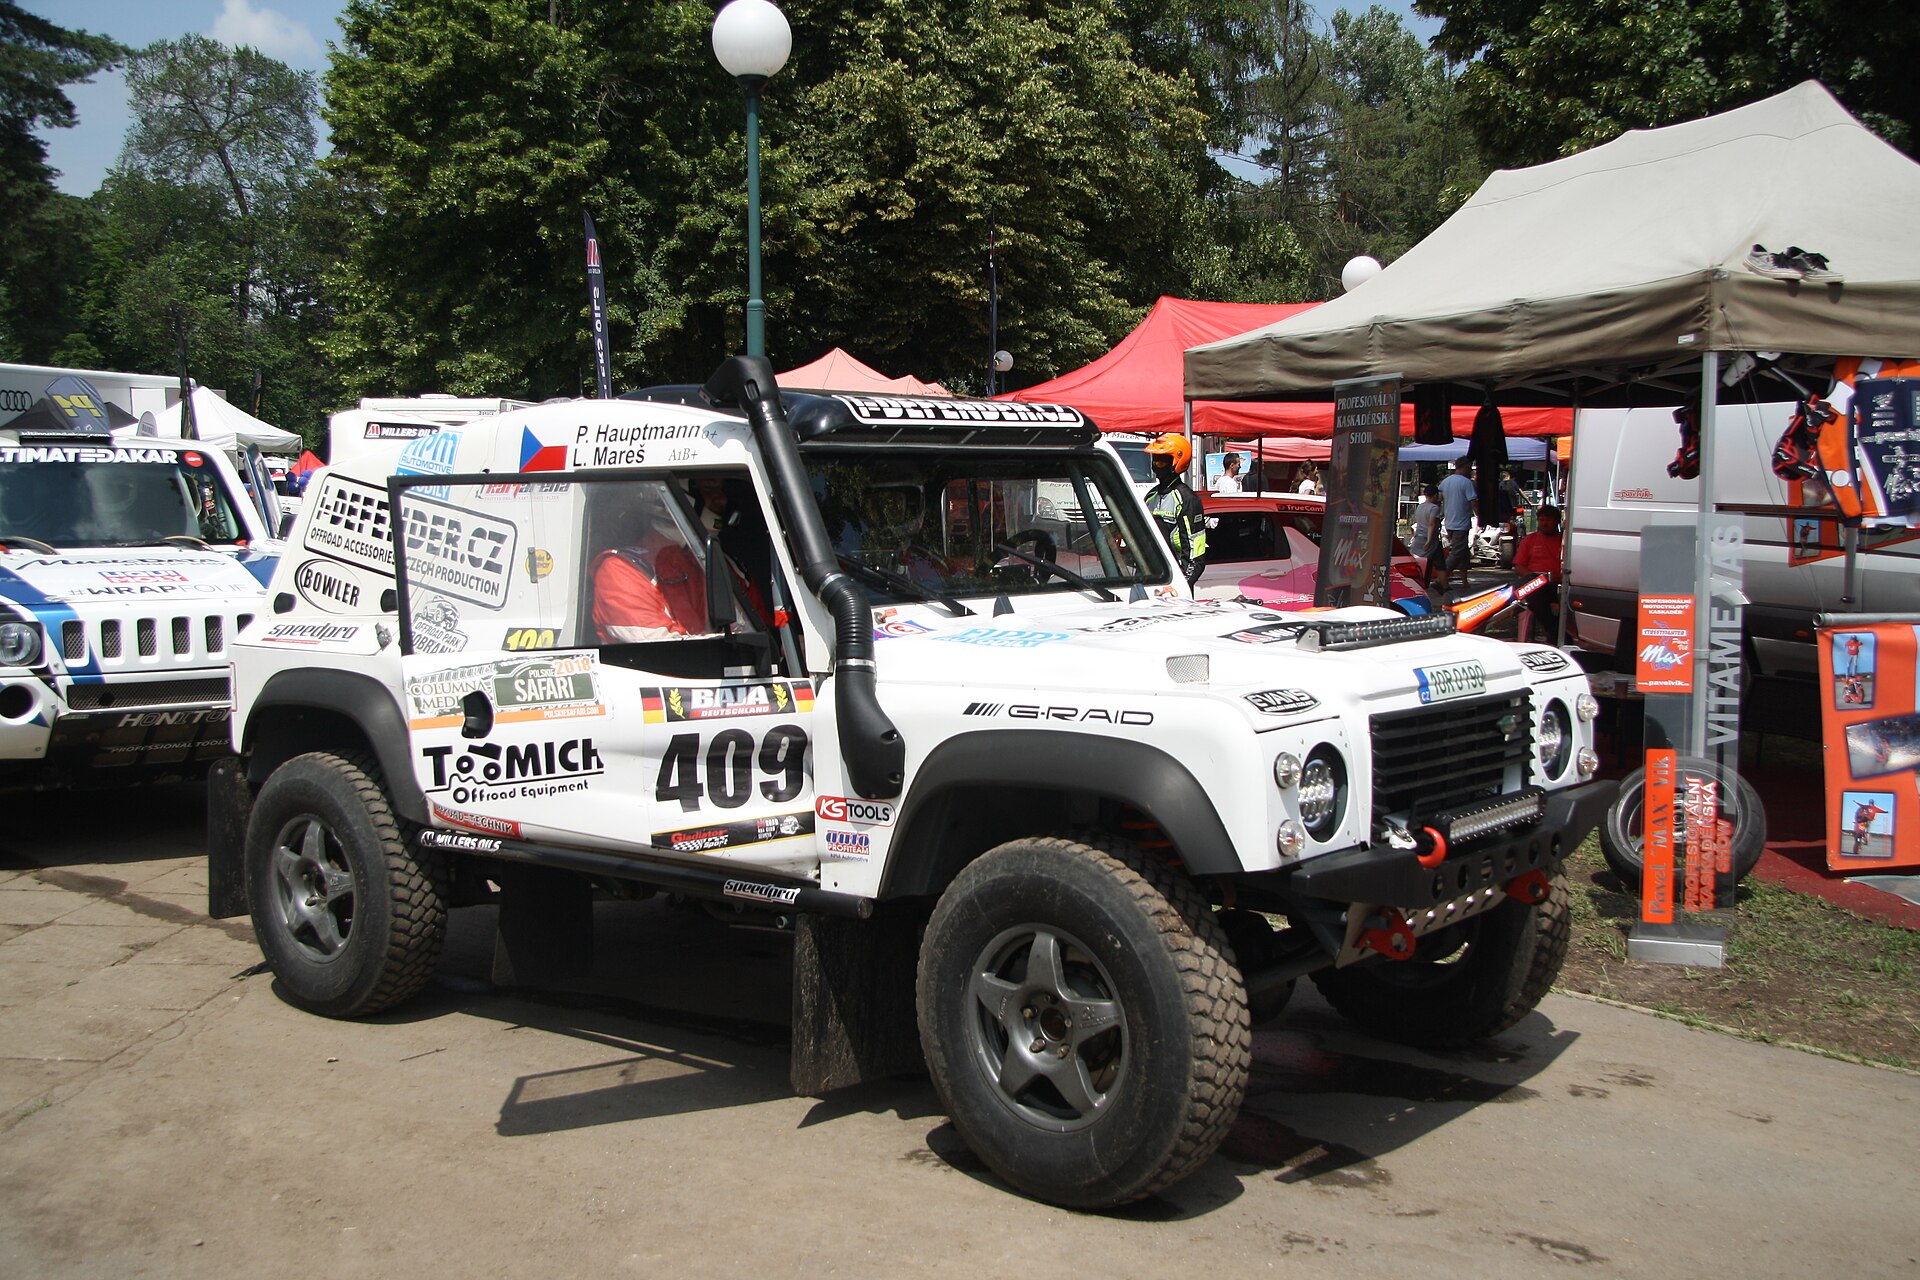
Two Wildcats fitted by BAE Systems with drive-by-wire controls, computers and terrain sensors for autonomous-vehicle research.

Difflocked · free browser gamePlay & customise vintage 4×4s →Race classic 4×4s, build your own and keep it in your garage. Free, in the browser.
BASE VEHICLEWildcat (1998–2007)BUILT BYBowlerIN SERVICE2010OPERATED INUnited KingdomPRODUCTION2LAYOUT4 wheels · 100″

The record

BAE Systems retrofitted two Wildcats with drive-by-wire controls, high-performance computing and lidar and camera sensors. One served the BAE Systems Advanced Technology Centre's autonomous systems research; the other went to the Mobile Robotics Group at Oxford University for its work on navigation without GPS.

Research status: draft — identification, dates or figures could not all be pinned down; the summary says what is unresolved.

Specification

MANUFACTURERBowler ↗
Belper
MANUFACTUREDc. 2010
ENGINENot publishedRover V8
PRODUCTION RUN2
COUNTRY OF ORIGINUnited Kingdom
OPERATED INUnited Kingdom
STATUSresearch vehicles
RECORD KINDNamed model
MODEL LINEWildcat
FAMILYWildcat
WHEELS4
NOMINAL WHEELBASE100″
BODY STYLErally-raid

Catalogue fields describe the vehicle's structure and body as this registry records it. They are not certified factory measurements, and no performance figures are published here.
Variants & colours

Base model variants

AI rendering impression

An AI rendering impression starts from a 3D model of this vehicle, which an image model then paints into a scene. It is an artist's impression of the type, made to give a feel for the vehicle in its element — not a photograph, and not a record of any particular vehicle.

Proportions, fittings, markings, colours and the setting can all drift from the original in the process. For the vehicle's actual details, rely on the specification, the photographs and the cited sources on this page.

Sources

  1. 1Bowler Wildcat ↗Wikipedia · accessed 2026-09-24SOURCE

Registry record updated 2026-09-24 · status: draft